
2019-2020 VEX Season – Tower Takeover
VEX Robotics Competition Tower Takeover is played on a 12’x12’ square field configured as seen above. Two alliances – one red and one blue – composed of two teams each, compete in matches consisting of a 15 second autonomous period, followed by a 1:45 driver controlled period.
The object of the game is to attain a higher score than the opposing alliance by placing cubes in towers, or scoring cubes in goals.

Videos
Participating teams
| Team | Robot name |
|---|---|
| 254A | — |
| 254B | — |
| 254D | — |
| 254F | — |
| 254R | — |
| 254W | — |
| 254X | — |
Team 254A
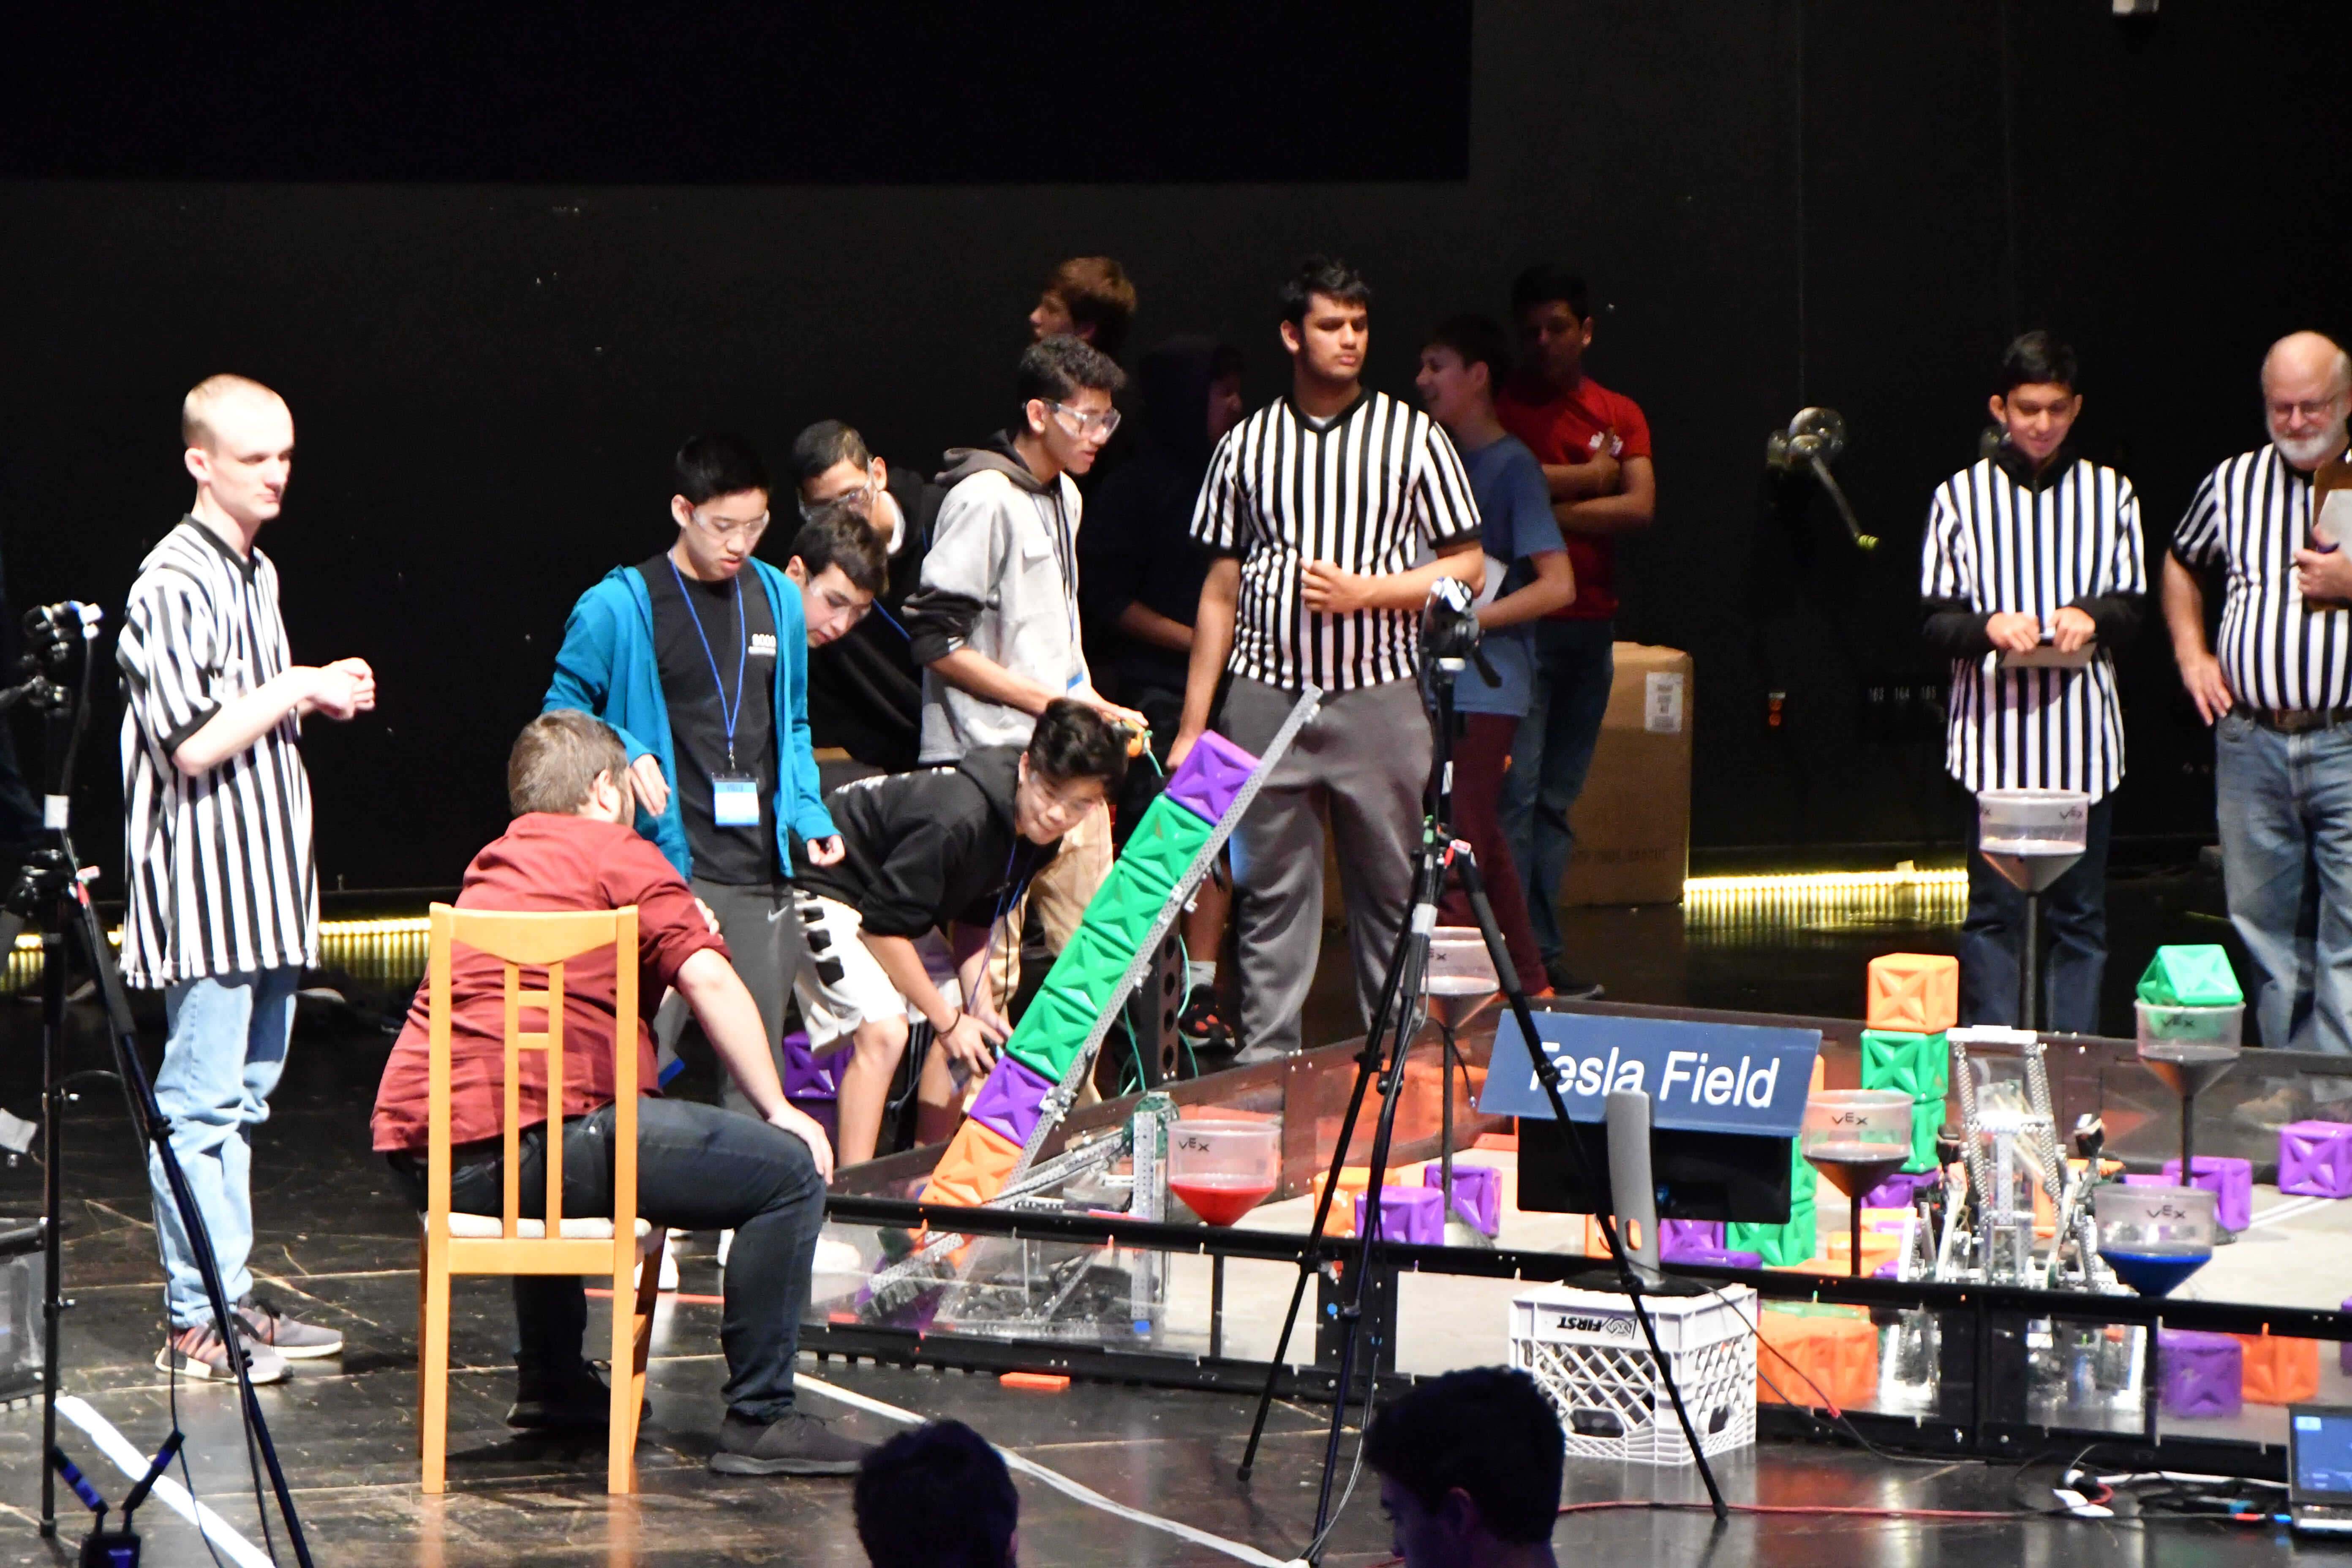
This robot is solely a tray robot for now. It sucks up cubes with a set of two rollers and stacks them on a massive tray. This design is very efficient at making large towers of cubes and placing them in the scoring zones. Because the rollers spin at high speeds, this robot is able to pick up all the cubes incredibly fast. In the future we plan to add arms to our rollers so that the robot is able to place cubes in the towers.
Team 254B

This robot is focused on stacking cubes. It uses its rollers to grab any nearby cubes and feed them into the tray. The low angle of the tray allows the cubes to be stacked easily and quickly. The smaller drive base makes the robot more maneuverable and allows the robot to place the cubes in the scoring zones easily.
Team 254D

This robot utilizes the stacking power of a tray robot but is also able to score cubes in the towers. The rollers are mounted on a very simple but study arm system which allows it to lift the cubes into the towers. The drive base is small and geared for speed to be able to maneuver quickly around the field and avoid defense. The extremely low angle of the tray makes this robot very quick at intaking the cubes, but it also lowers the center of gravity, further increasing this robot’s maneuverability.
Team 254F

Our robot’s purpose is to slow down or prevent our opponents from scoring while quickly scoring cubes in the towers. Our drive-base utilizes 6 motors to be able to push our opponents away from their scoring zones or towers. Our arm and claw can rotate quickly from the back to the front of our robot to score cubes in both, the towers and scoring zones at a fast pace. We use a vision sensor and an inertia sensor to aid in our autonomous program.
Team 254R

Our robot uses a lift and a tube like intake to lift and stack four cubes at one time. We can place cubes in the towers quickly and stack on top of pre-existing stacks. Our intake design allows us to pick up the tower of four cubes closest to our protected zone in one movement. In competition, we have realized some flaws in our design and may build a robot that can stack faster.
Team 254X

This robot has a tray to maximize its efficiency at collecting and stacking cubes, but it is mounted on a massive reverse-double six bar. This lift lets the robot stack on pre-existing stacks up to 9 cubes tall. The reverse-double six bar design give the robot the height but it also provides great stability with its strictly linear range of motion.